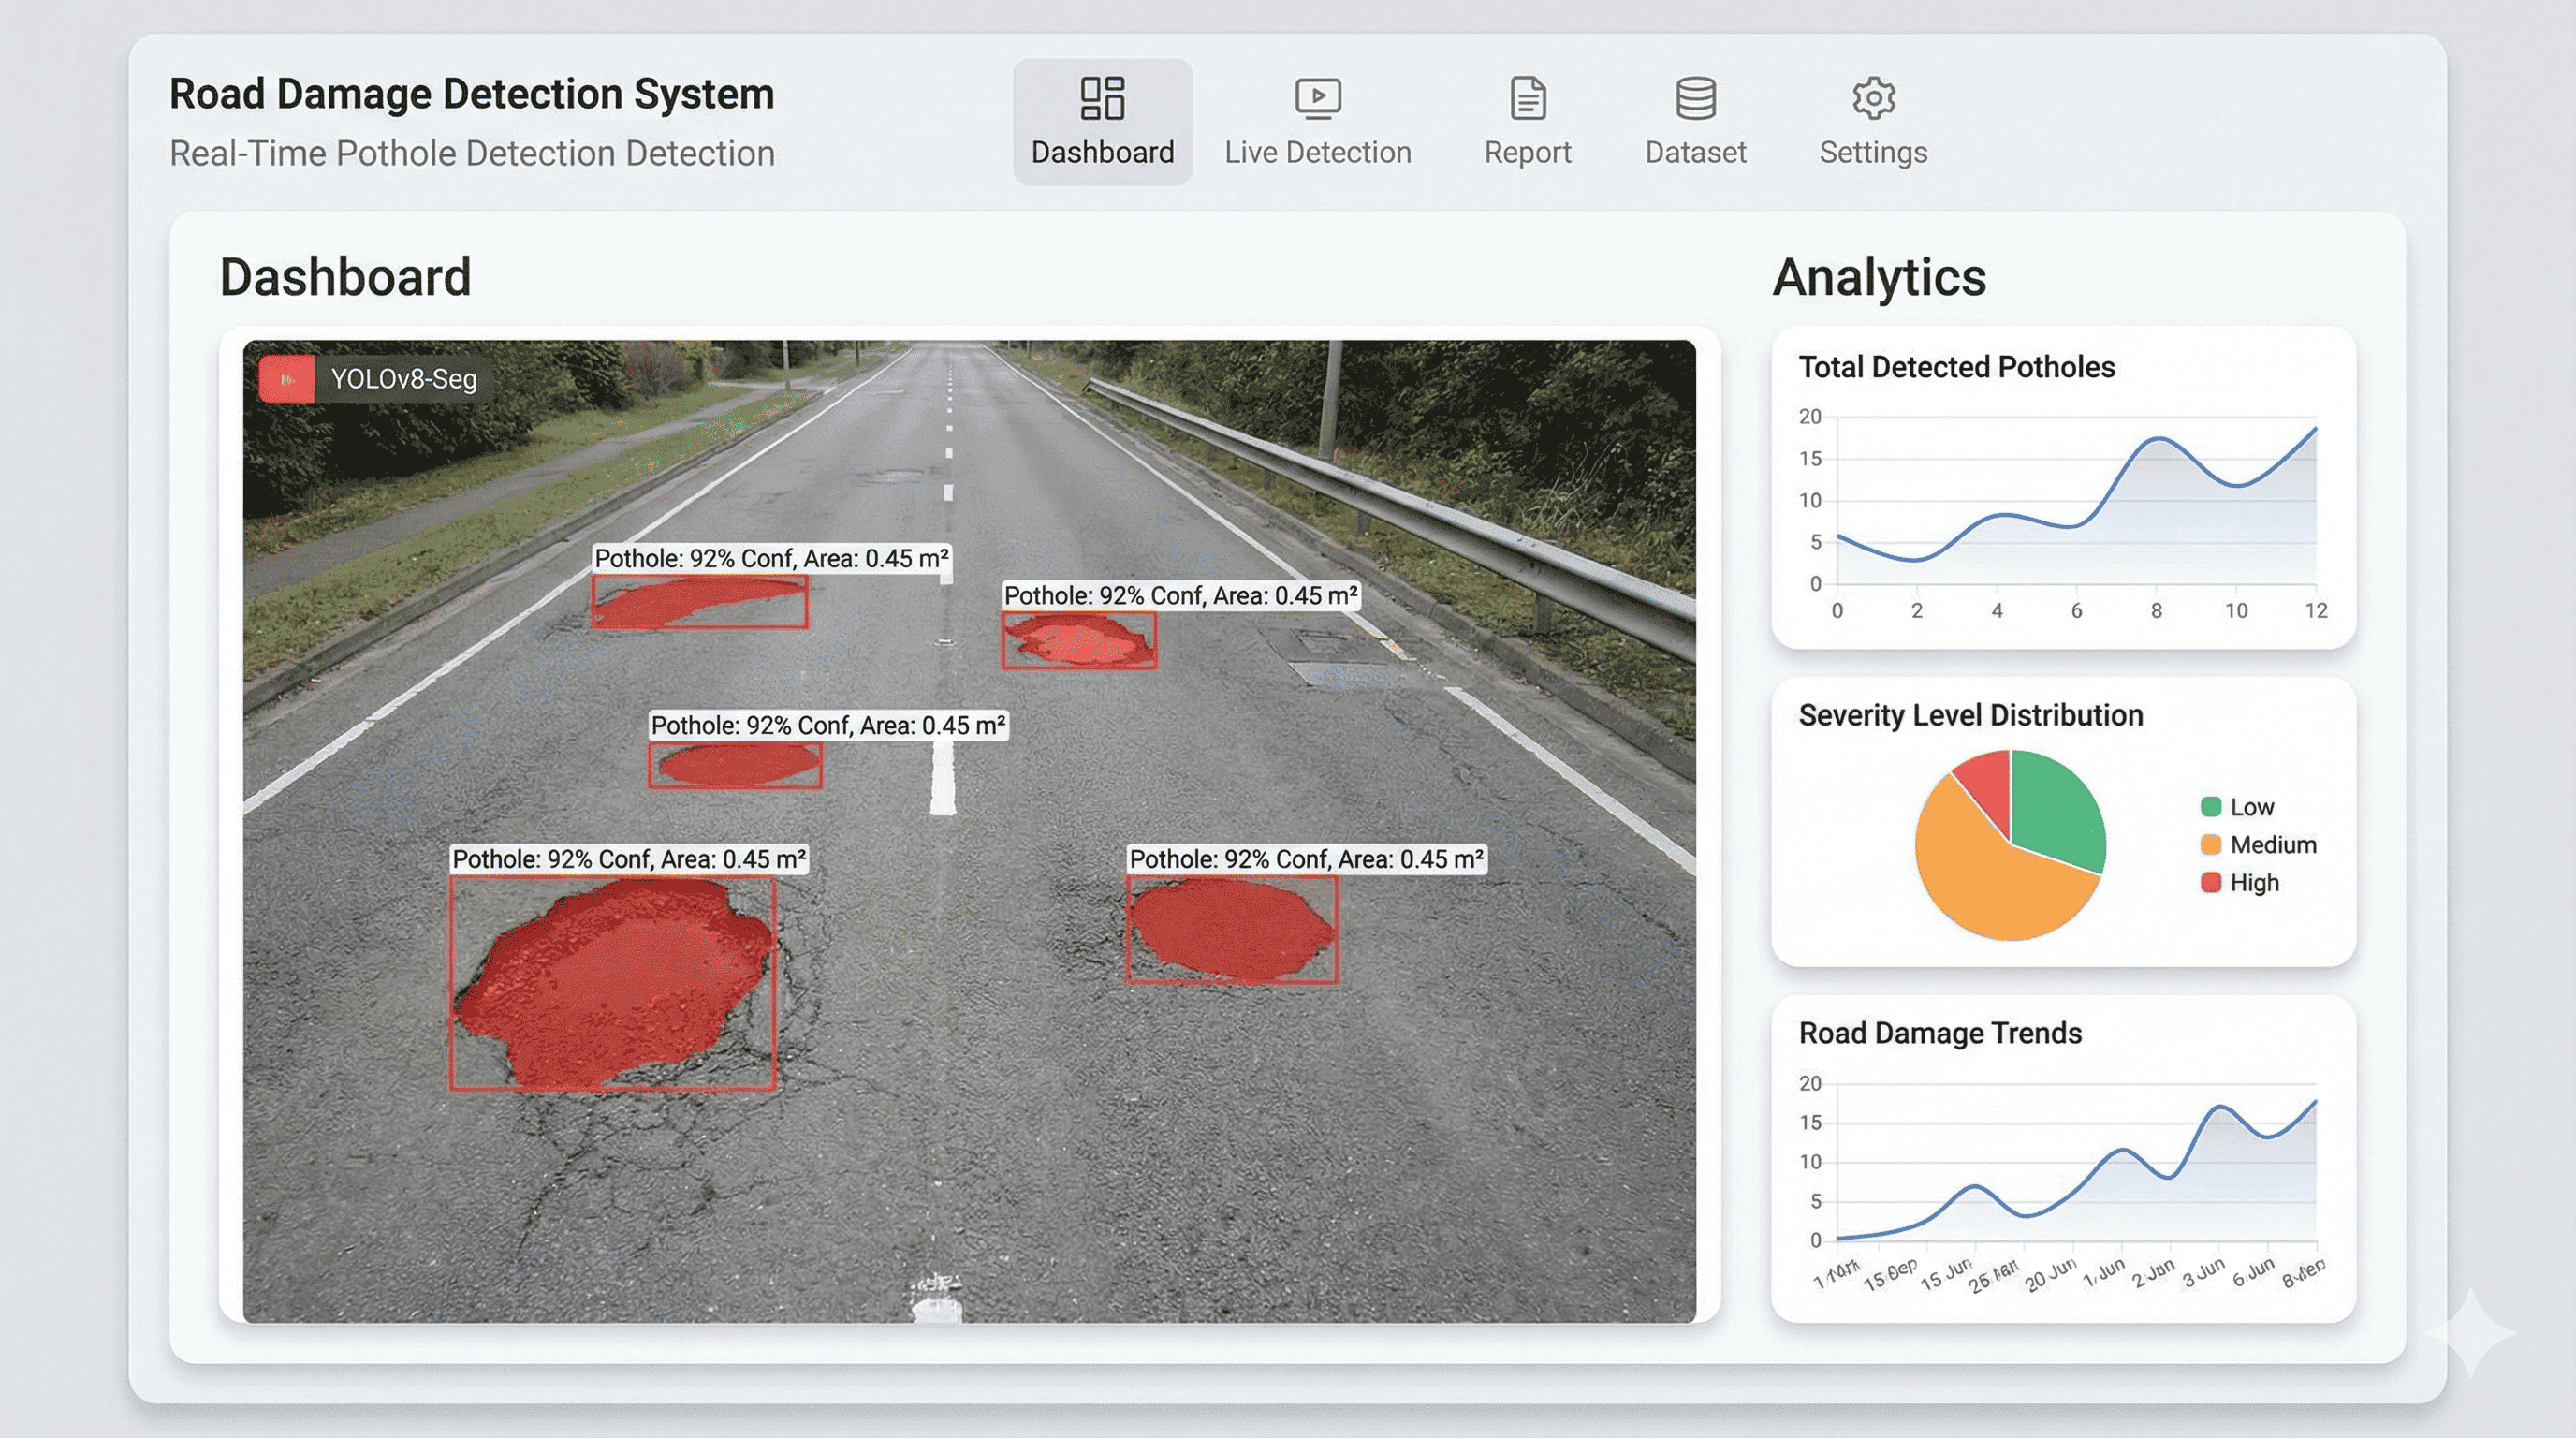
RoadScan: Real-time Pothole Segmentation & Area Estimation
Project Gallery
Project Documentation
RoadScan: Real-time Pothole Segmentation & Area Estimation
Overview
RoadScan is an advanced computer vision system developed as thesis research to address the critical challenge of road maintenance efficiency. Unlike conventional detection methods that rely on simple bounding boxes, this solution employs instance segmentation to identify and analyze road surface defects with pixel-level precision.
The system leverages the state-of-the-art YOLOv8-seg architecture to perform real-time pothole detection, segmentation, and quantitative area estimation—providing infrastructure analysts with actionable metrics for maintenance prioritization.
Key Capabilities
| Feature | Description |
|---|---|
| Real-time Detection | Processes live webcam feeds and video files with minimal latency |
| Instance Segmentation | Generates pixel-accurate masks for each detected pothole |
| Area Quantification | Calculates precise defect areas in square pixels for severity assessment |
| Interactive Interface | User-friendly web application for seamless analysis workflow |
Technical Architecture
Core AI & Computer Vision
| Technology | Purpose |
|---|---|
| Python | Primary development language for model integration and logic |
| YOLOv8-seg (Ultralytics) | State-of-the-art instance segmentation model |
| OpenCV | Image preprocessing, contour extraction, and visualization |
| PyTorch | Deep learning framework powering model inference |
Web Application & Data Processing
| Technology | Purpose |
|---|---|
| Streamlit | Rapid prototyping framework for interactive data applications |
| Streamlit-WebRTC | Real-time video stream handling within the browser |
| Pandas | Structured data manipulation and reporting |
| NumPy | High-performance numerical computations for area calculation |
Research Contribution
This project demonstrates the practical application of deep learning in civil infrastructure maintenance, offering a cost-effective alternative to manual road inspection methods. The segmentation-based approach provides more accurate damage assessment compared to traditional detection systems, enabling data-driven maintenance scheduling.
Workflow
┌─────────────────┐     ┌─────────────────┐     ┌─────────────────┐
│   Video Input   │────▶│   YOLOv8-seg    │────▶│   Segmentation  │
│  (Webcam/File)  │     │   Inference     │     │   Masks         │
└─────────────────┘     └─────────────────┘     └─────────────────┘
                                                       │
                                                       ▼
┌─────────────────┐     ┌─────────────────┐     ┌─────────────────┐
│   Dashboard     │◀────│   Area          │◀────│   Contour       │
│   Visualization │     │   Calculation   │     │   Extraction    │
└─────────────────┘     └─────────────────┘     └─────────────────┘
Technologies Used
- Python
- YOLOv8-seg (Ultralytics)
- OpenCV
- PyTorch
- Streamlit
- Streamlit-WebRTC
- Pandas
- NumPy